code:
var weight_ID;
action weight
{
	my.passable=on;
        my.invisible=on;
	my.tilt=90;

	phent_settype(my,PH_RIGID,PH_BOX);
	phent_setgroup(my,2);
	phent_setmass(my,100,PH_BOX);
	phent_setfriction(my,40);
	phent_setelasticity(my,50,10);
	phent_setdamping(my,20,20);

	weight_ID=phcon_add(PH_HINGE,my,you);
	phcon_setparams1(weight_ID,my.x,vector(1,0,0),nullvector);
	phcon_setparams2(weight_ID,nullvector,nullvector,nullvector);
}
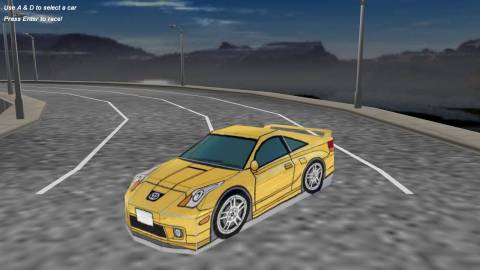
i added a passable weight below the car to make the center of gravity lower. it prevents that the car flips so easily. to connect it to the chassis i used a hinge with the limits set to 0.